I am a postdoc at Stanford University advised by Chelsea Finn. I am broadly interested in building general-purpose robots that can perform any tasks in the real-world, ranging from surgical to humanoid applications.
Previously, I focused on developing dextrous manipulation policies for the da Vinci robot with Axel Krieger. I also worked on developing autonomous surgical workflows for eye surgery with Marin Kobilarov and Iulian Iordachita. I interned at Zoox (self-driving company owned by Amazon) in the planning & controls and prediction team.
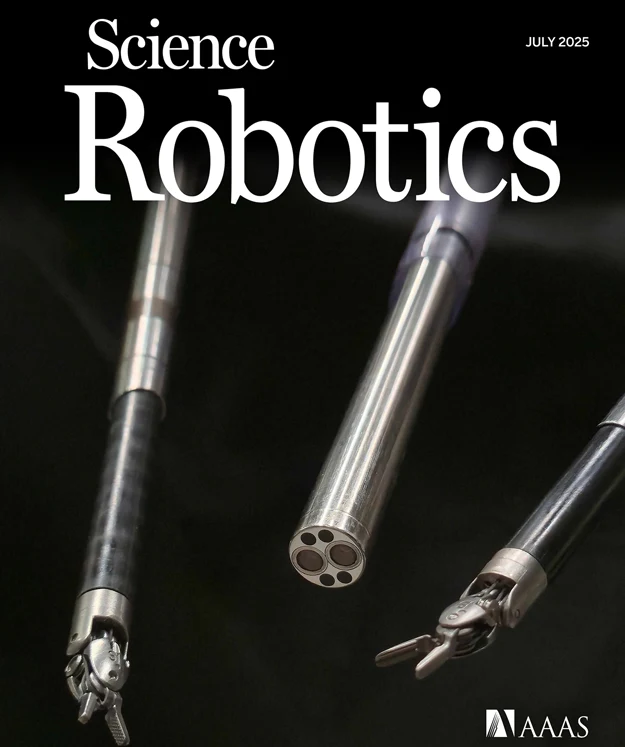
Our Science Robotics paper SRT-H made the July cover and ranked 2nd in Altmetric score among all Science Robotics papers. More than 280 news articles have been written about the work!
We show that we can teach robots new tasks, such as new sorting rules, skill composition, and rule-based ordering, via co-training with human data. This is useful because if you want to steer your robot to perform new tasks, you can simply collect human data rather than further robot data.
We explore whether surgical manipulation tasks can be learned on the da Vinci system via imitation learning. IL on da Vinci turns out to be non-trivial, due to forward kinematics errors that can reach +/- 5cm.
Pascal Hansen, Ji Woong Kim, Antony Goldenberg, Juo-Tung Chen, Yuanzhe Amos Li, Anton Deguet, Brandon White, De Ru Tsai, Richard Cha, Jeffrey Jopling, Paul Maria Scheikl, Axel Krieger
Ji Woong Kim, Juo-Tung Chen, Pascal Hansen, Lucy X. Shi, Antony Goldenberg, Samuel Schmidgall, Paul Maria Scheikl, Anton Deguet, Brandon M. White, De Ru Tsai, Richard Cha, Jeffrey Jopling, Chelsea Finn, Axel Krieger
Noah Barnes, Ji Woong Kim, Lingyun Di, Hannah Qu, Anuruddha Bhattacharjee, Miroslaw Janowski, Dheeraj Gandhi, Bailey Felix, Shaopeng Jiang, Olivia Young, Mark Fuge, Ryan D. Sochol, Jeremy D. Brown, Axel Krieger
Samuel Schmidgall, Carl Harris, Ime Essien, Daniel Olshvang, Tawsifur Rahman, Ji Woong Kim, Rojin Ziaei, Jason Eshraghian, Peter Abadir, Rama Chellappa